Mecanum Odometry ACTIVE
About
A decoupled odometry chain for a holonomic mobile base running on four Mecanum wheels. Mecanum wheels buy omnidirectional motion without steering, and pay for it with systematic transverse slip and dynamic crushing of the rollers: odometry read from the drive motors is unusable in practice.
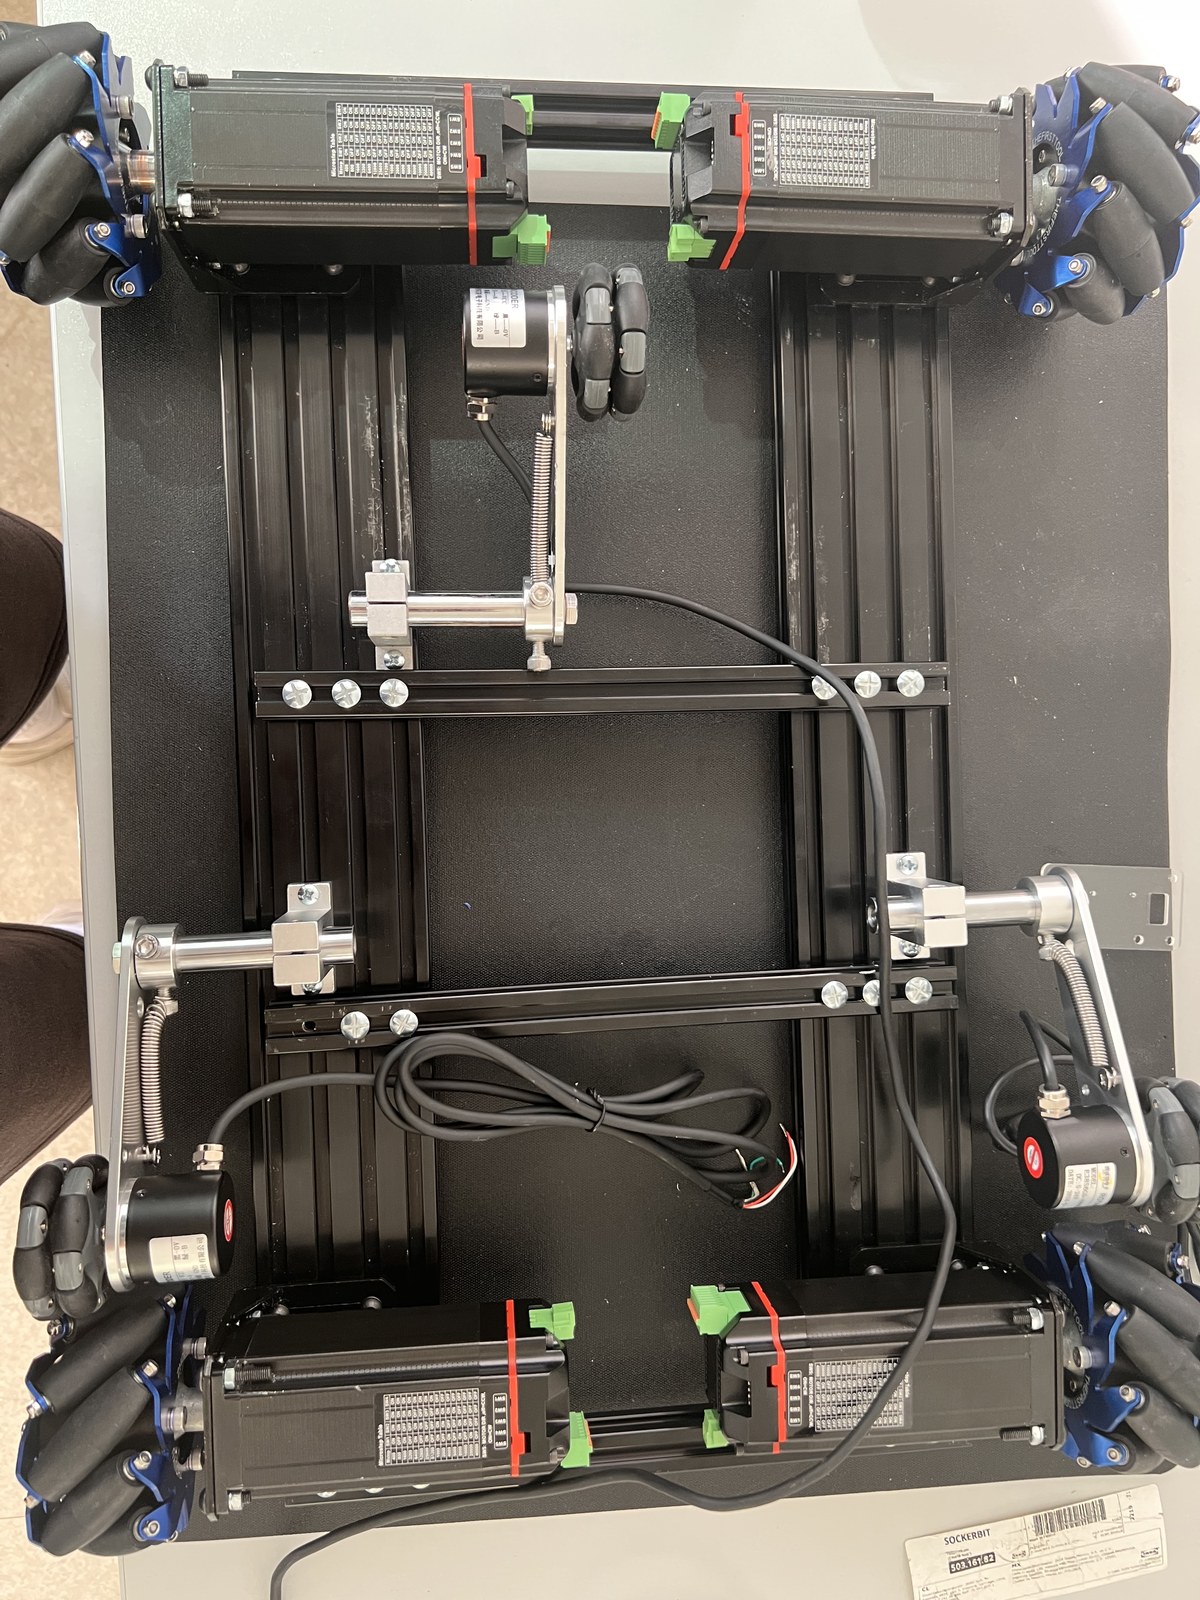
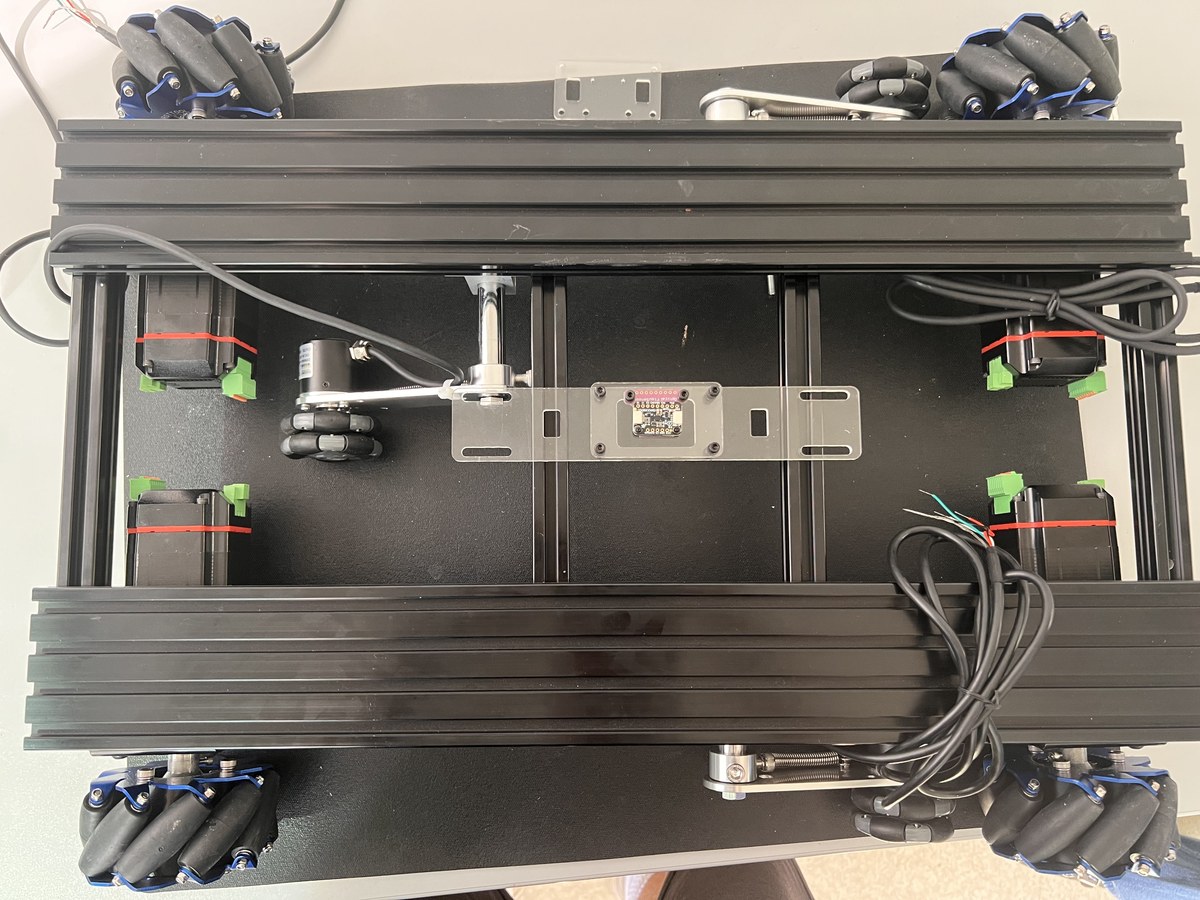
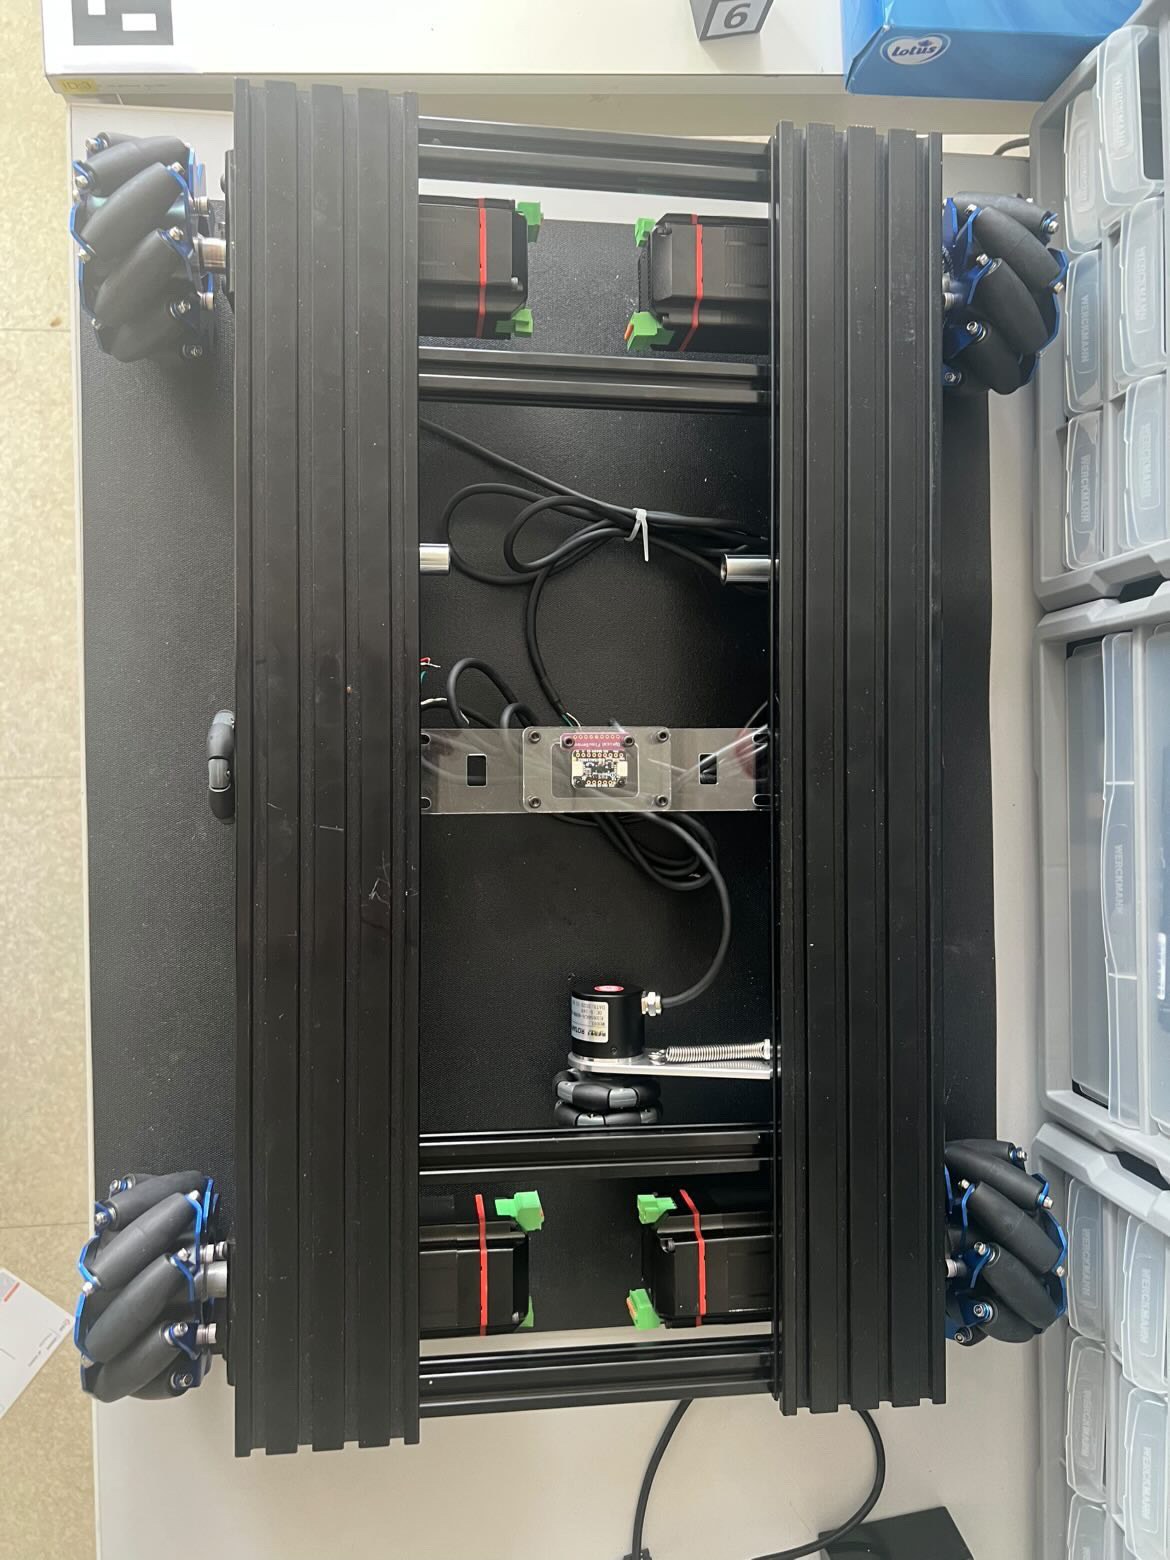
The answer adopted here separates measurement from propulsion. Three omnidirectional encoder wheels, suspended on articulated arms so they stay in contact without bearing load, provide the measurement, together with an inertial unit. The work covers the direct and inverse kinematic models, the homogenisation and conditioning of the Jacobian matrix, the optimal placement of the sensors — an isotropic distribution at 120° — and of the IMU, the CAD model of the structure under FreeCAD, and the embedded implementation on Arduino.
The answer adopted here separates measurement from propulsion. Three omnidirectional encoder wheels, suspended on articulated arms so they stay in contact without bearing load, provide the measurement, together with an inertial unit. The work covers the direct and inverse kinematic models, the homogenisation and conditioning of the Jacobian matrix, the optimal placement of the sensors — an isotropic distribution at 120° — and of the IMU, the CAD model of the structure under FreeCAD, and the embedded implementation on Arduino.
Gallery