6D Force and Torque Sensor ACTIVE
About
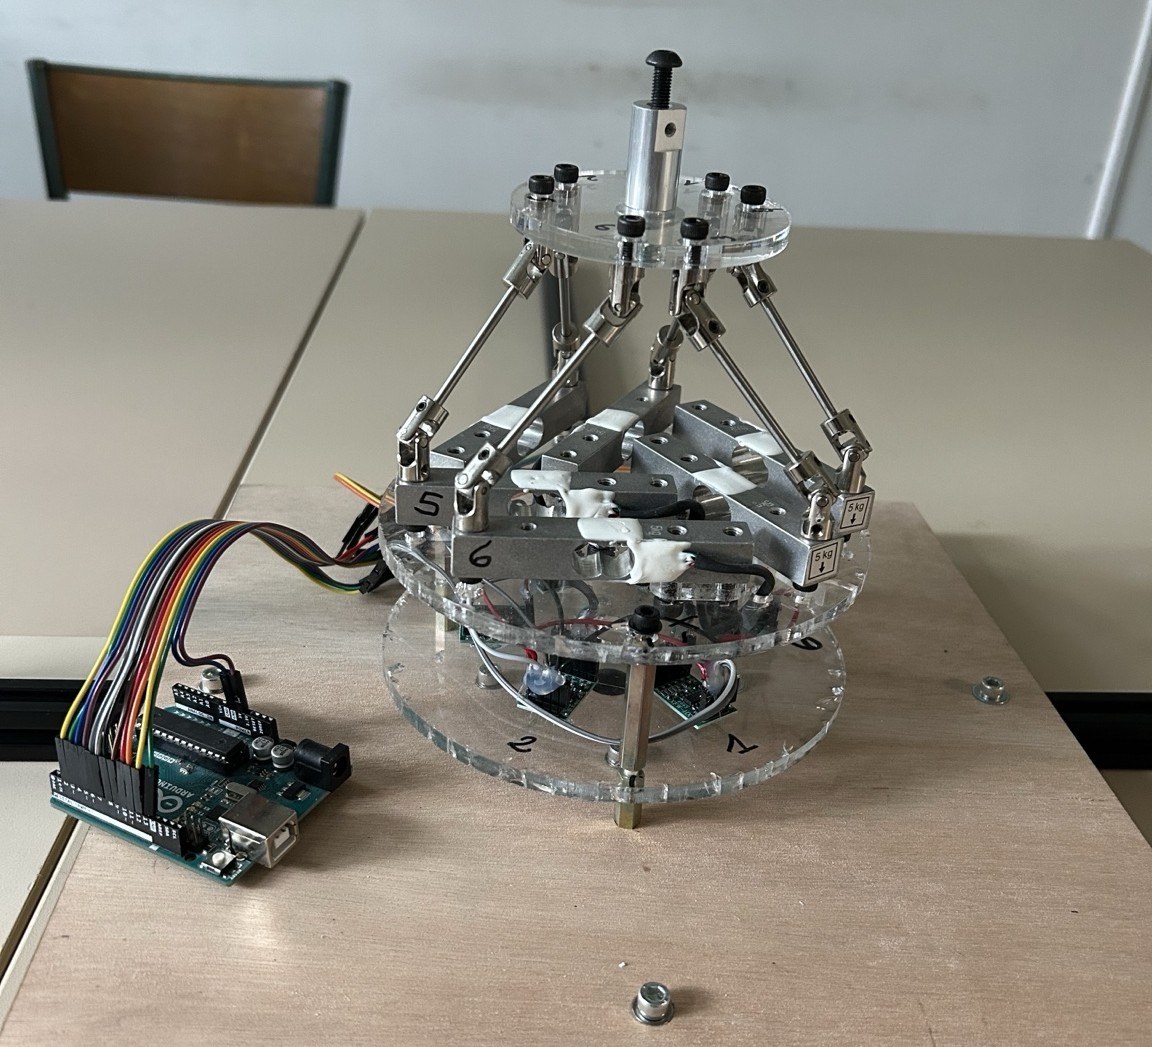
A six-axis force and torque sensor built on a Stewart platform architecture, reconstructing the three force components (Fx, Fy, Fz) and the three torque components (Mx, My, Mz) from uniaxial load cells alone.
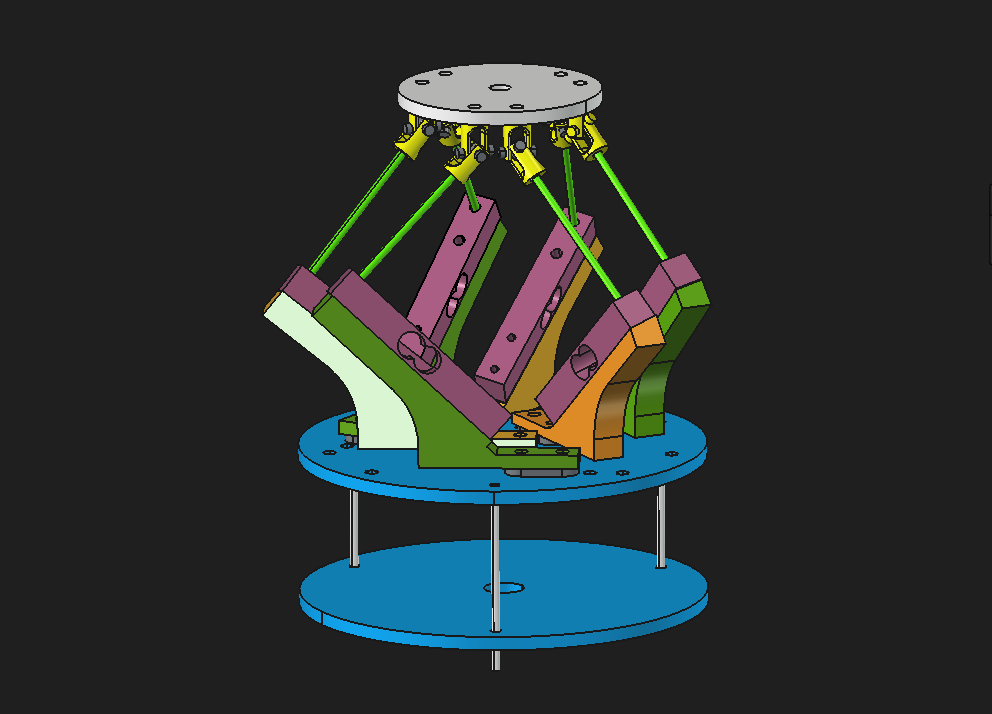
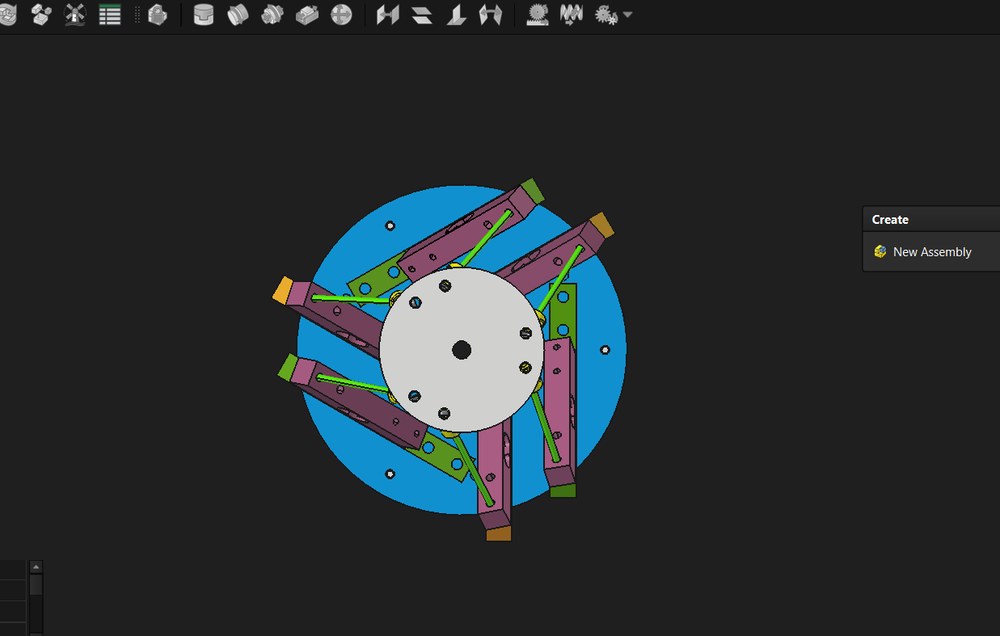
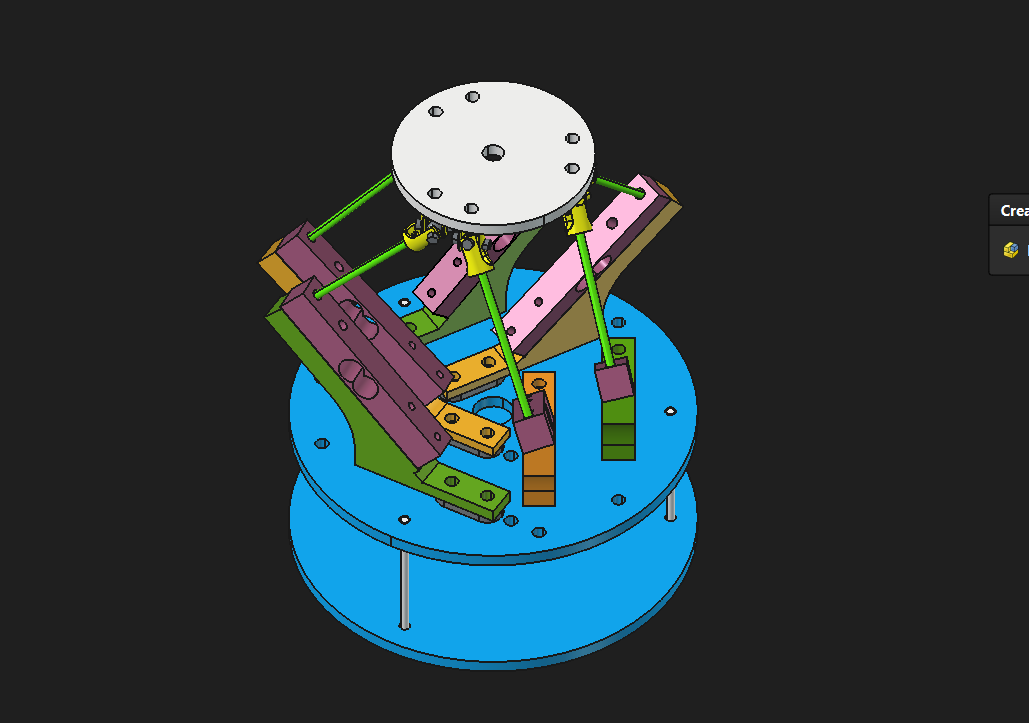
The design starts from a diagnosis of an earlier prototype: the measurement errors it produced were traced to the geometry of its cell arrangement. The new mechanical design, modelled under FreeCAD, places the load cells at an incline so that each axis contributes to several measurements. It comes with the geometric and mathematical model of the system, an acquisition chain built on Arduino and HX711 amplifiers, a least-squares calibration method, and digital filtering — a Butterworth low-pass and a Kalman filter — to separate the signal from the noise of the cells.
The design starts from a diagnosis of an earlier prototype: the measurement errors it produced were traced to the geometry of its cell arrangement. The new mechanical design, modelled under FreeCAD, places the load cells at an incline so that each axis contributes to several measurements. It comes with the geometric and mathematical model of the system, an acquisition chain built on Arduino and HX711 amplifiers, a least-squares calibration method, and digital filtering — a Butterworth low-pass and a Kalman filter — to separate the signal from the noise of the cells.
Gallery