CNC Suction Robot ACTIVE
About
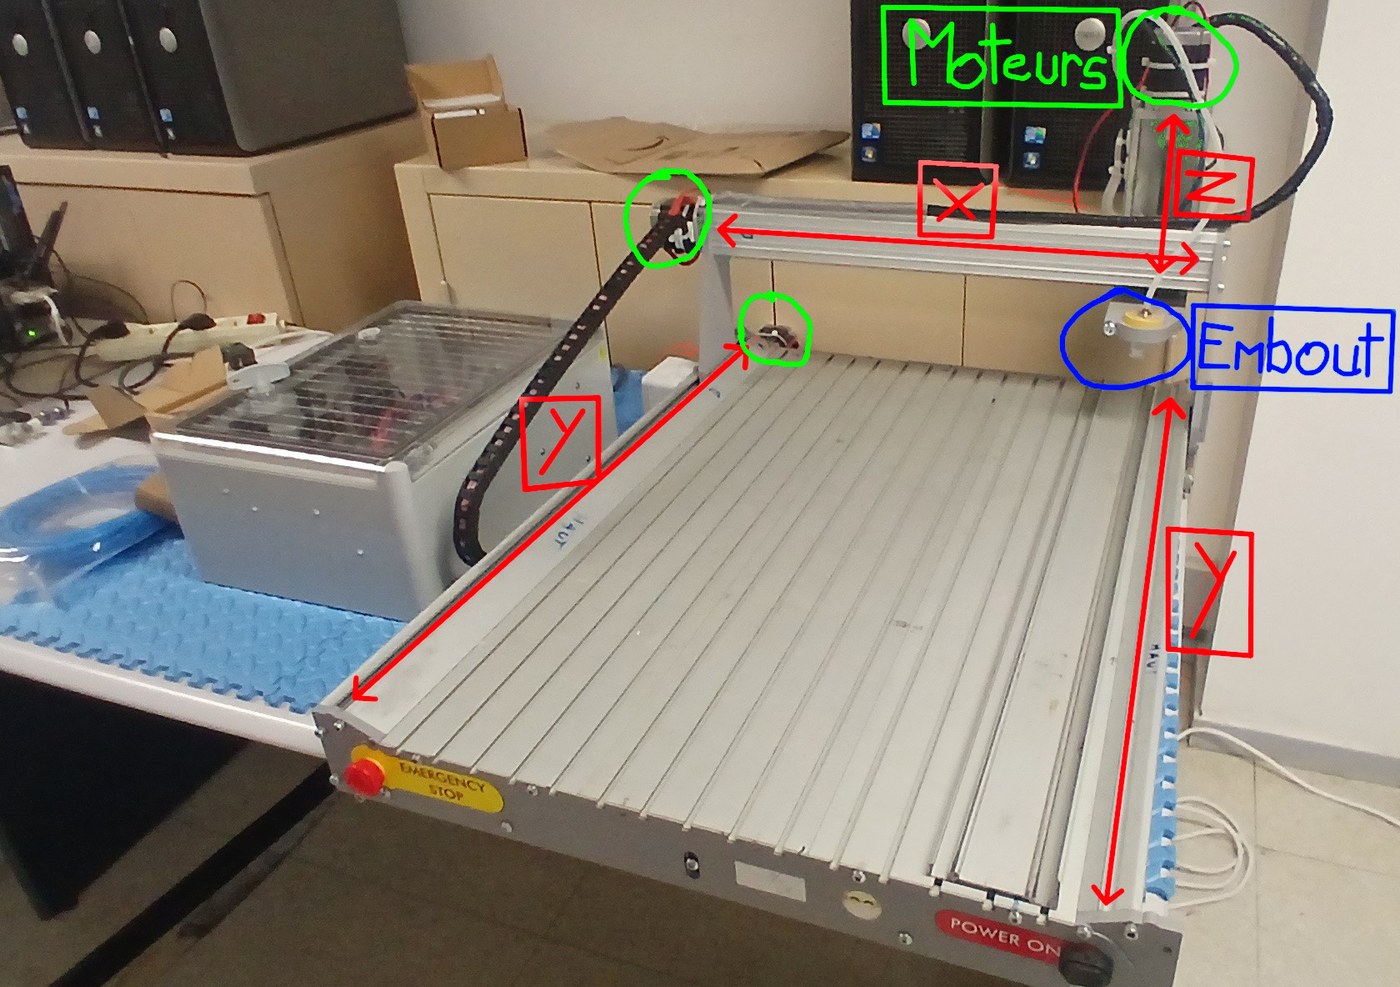
A numerically controlled machine converted into a suction-gripper manipulator, serving as the physical platform for experiments in epistemic planning applied to human-robot collaboration. Industrial arms are priced out of academic reach and expose proprietary interfaces that do not lend themselves to being driven by an external planner; reusing a CNC already in the laboratory keeps precise mechanics and an open control system, at the cost of a substantial adaptation effort.
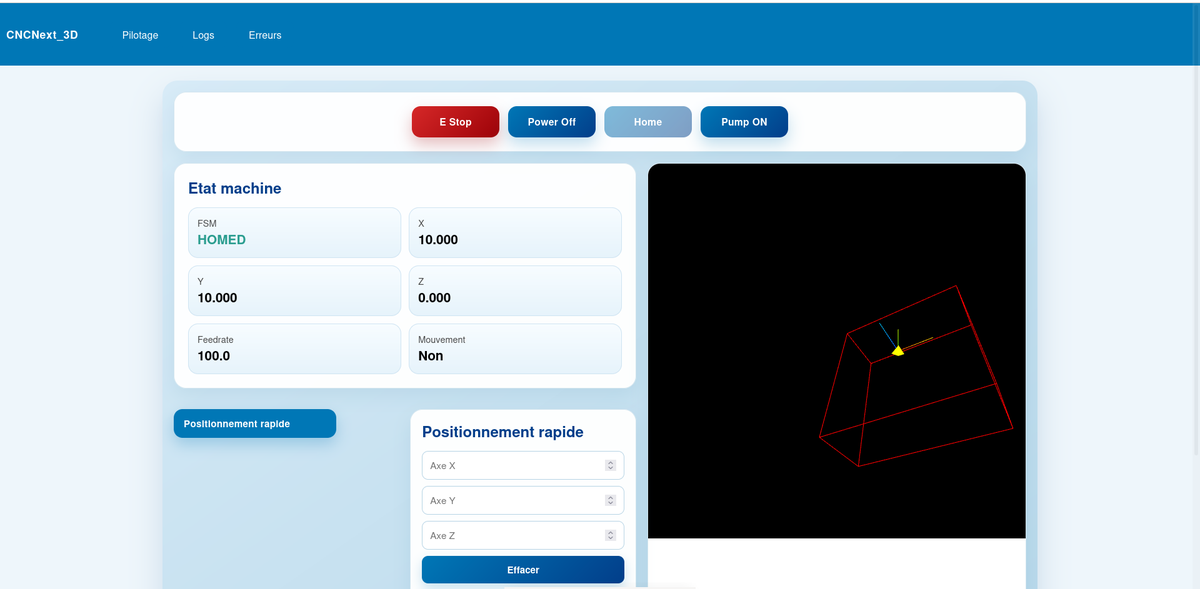
The machine keeps its LinuxCNC control chain (HAL, RTAPI, GCode) and gains a pneumatic suction gripper. Above it sits a control layer that lets an external program — typically a planner — issue commands, read the machine state and supervise execution without ever touching GCode. The system is modelled as a finite state machine and exposes three interfaces: a command line, a Python API and a web interface, with movement synchronisation, command validation and safety mechanisms including an emergency stop.
The aim is not the collaboration experiment itself but the apparatus it will run on: a reusable, documented brick that a third-party program can drive simply.
Gallery